
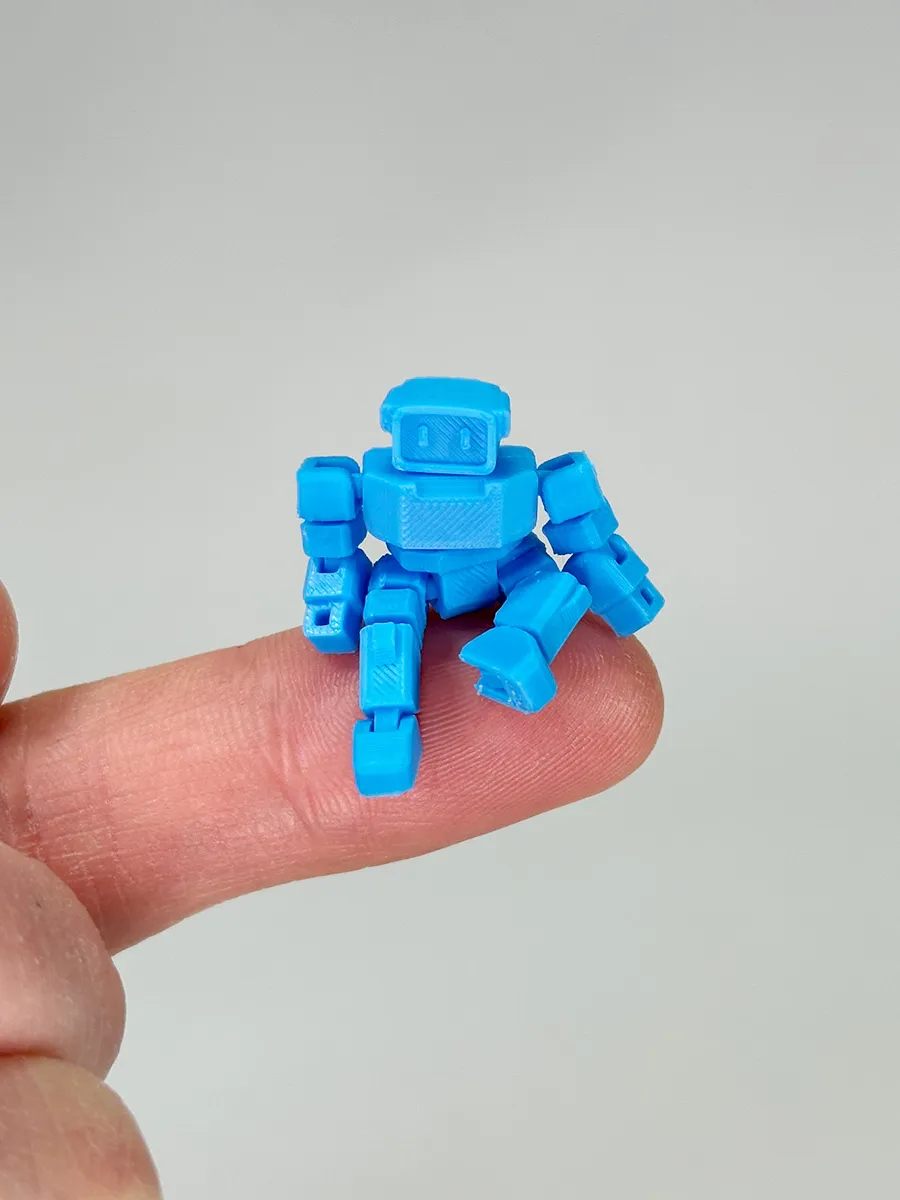
Model Overview & Print Notes
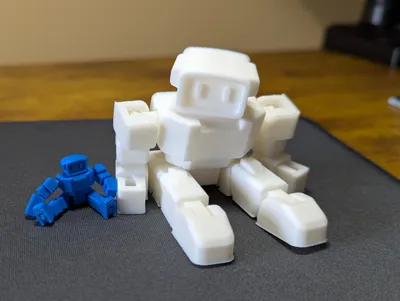
Hi, this time I brought a new design, the robot E. This is a brand - new challenge. I tried to make it as small as possible. It has 20 movable joints and is also print-in-place. Of course, if you want to print this extremely small robot E, a 0.2mm nozzle is required. I've also prepared a version that can be printed with a 0.4mm nozzle. Please pay attention to the instructions in the profile.
During the printing test of this tiny structure, I found that different printers or filament can lead to different results. To help more people print it successfully, I had to increase the gaps between the joints. In the version for the 0.4mm nozzle, I also adjusted the joint gap separately.If the joints cannot move, you can try enlarging the model a bit.
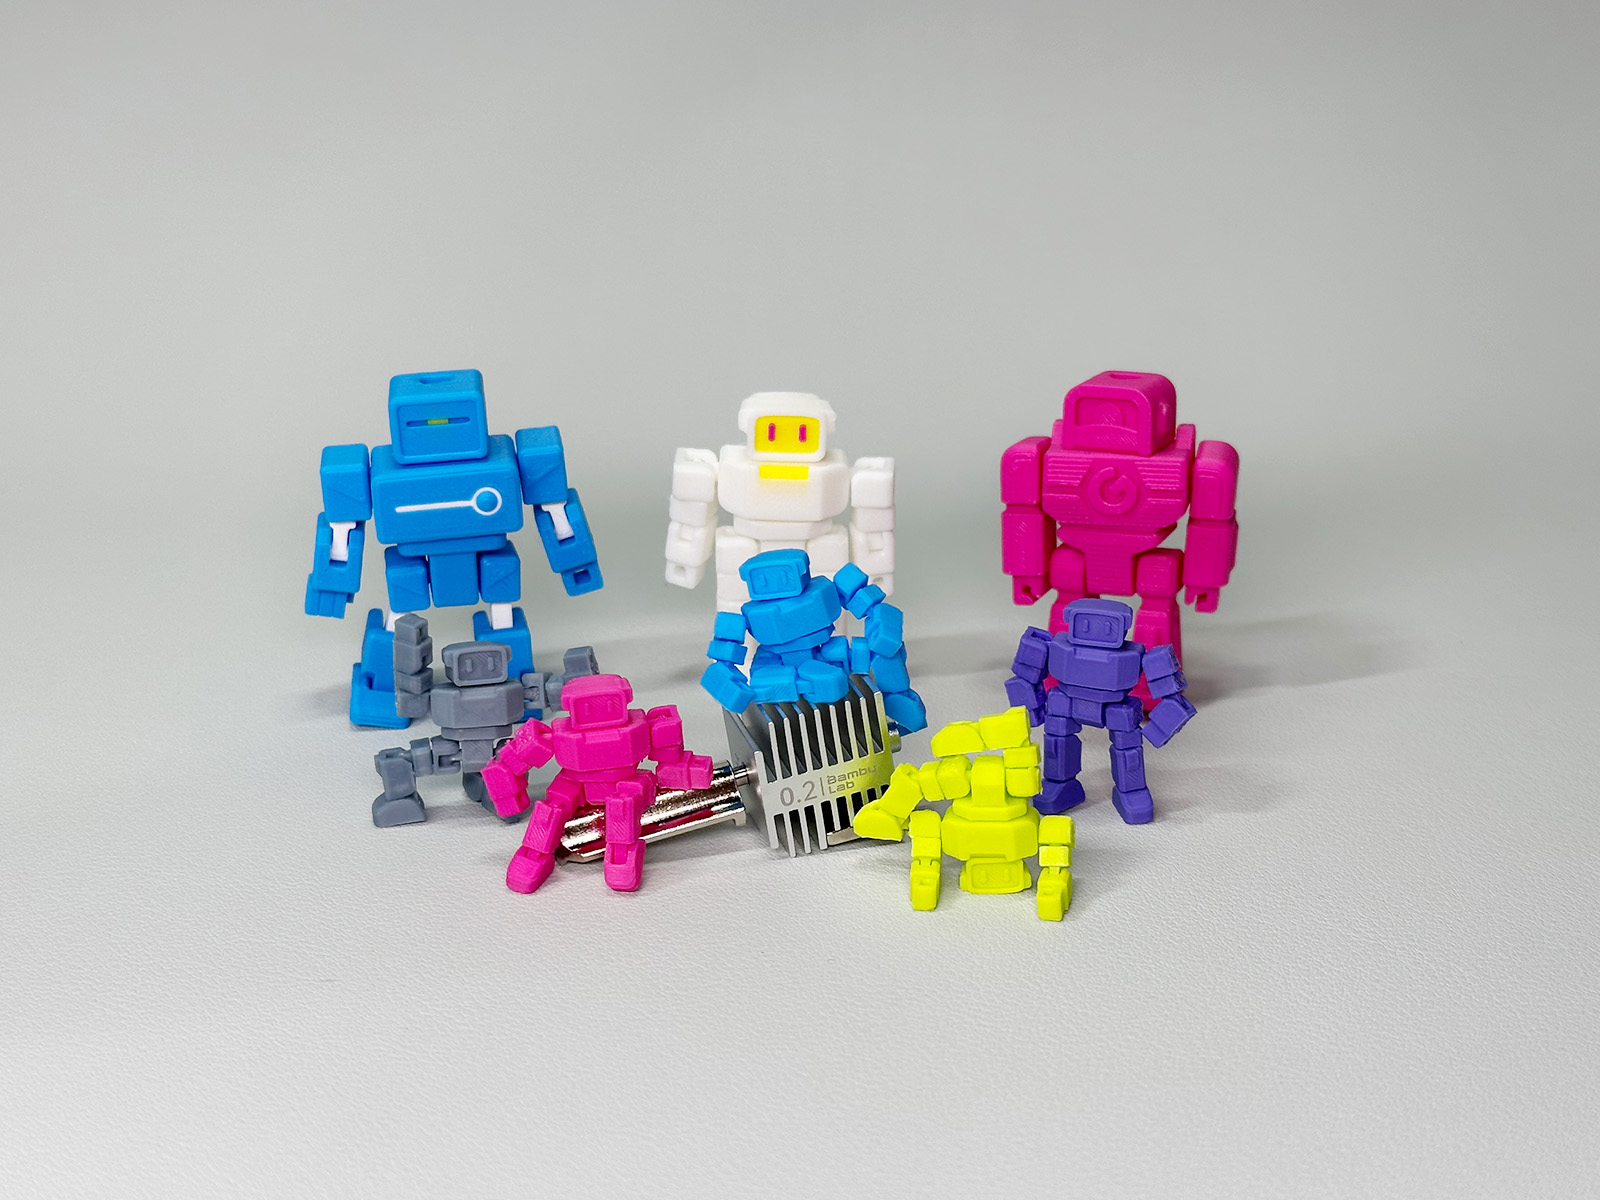
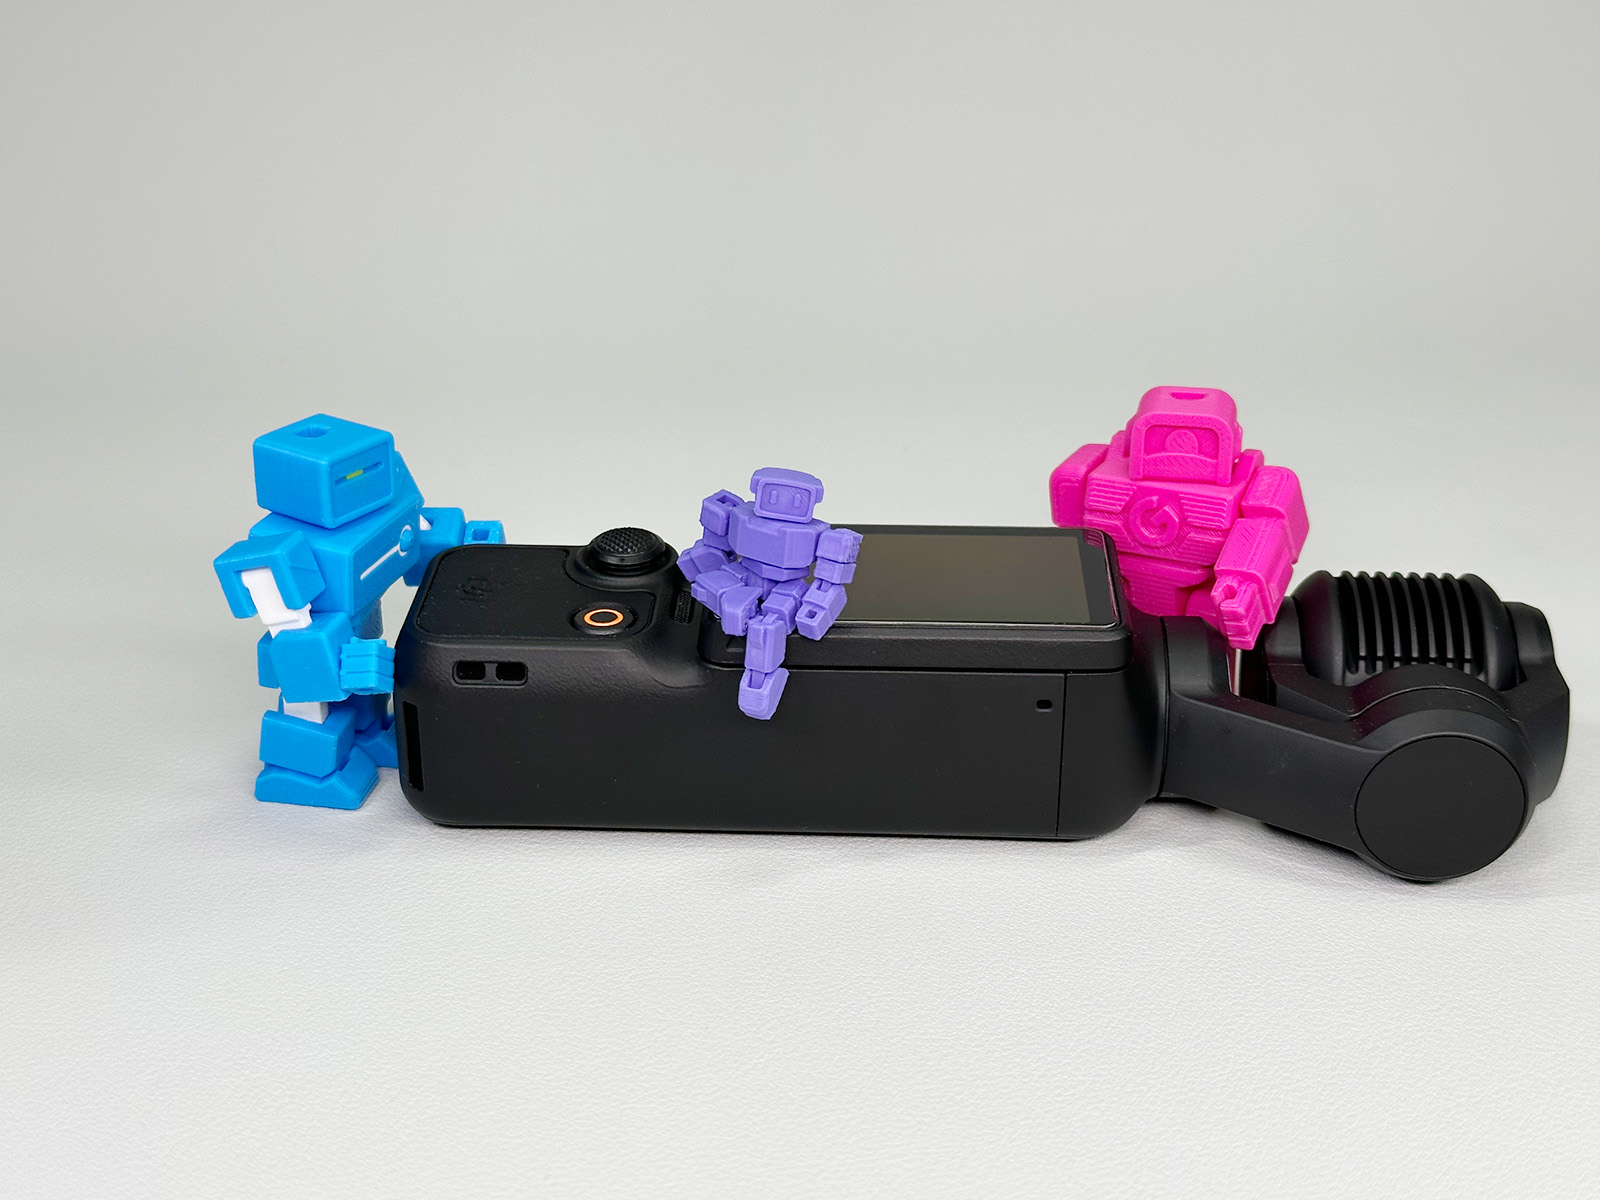
For other models of robots, you can click the link to find them:
You can use the AMS to achieve various personalized color combinations.
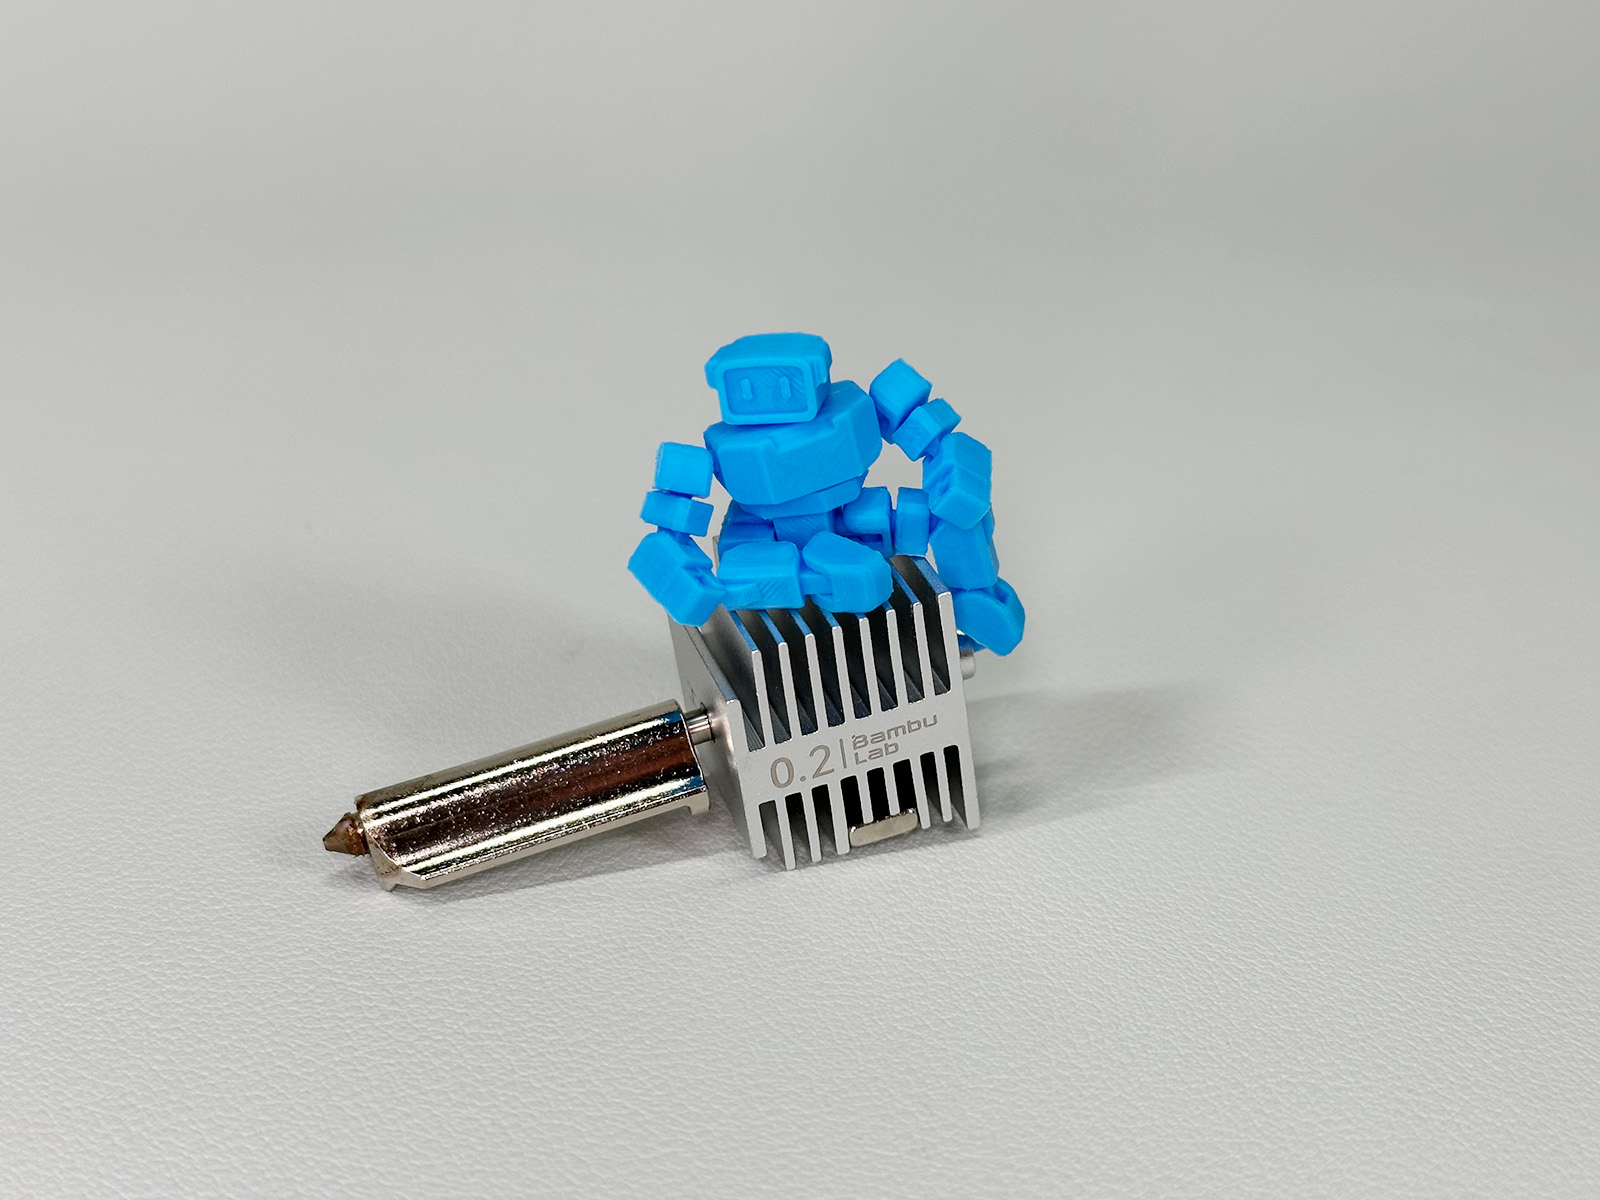
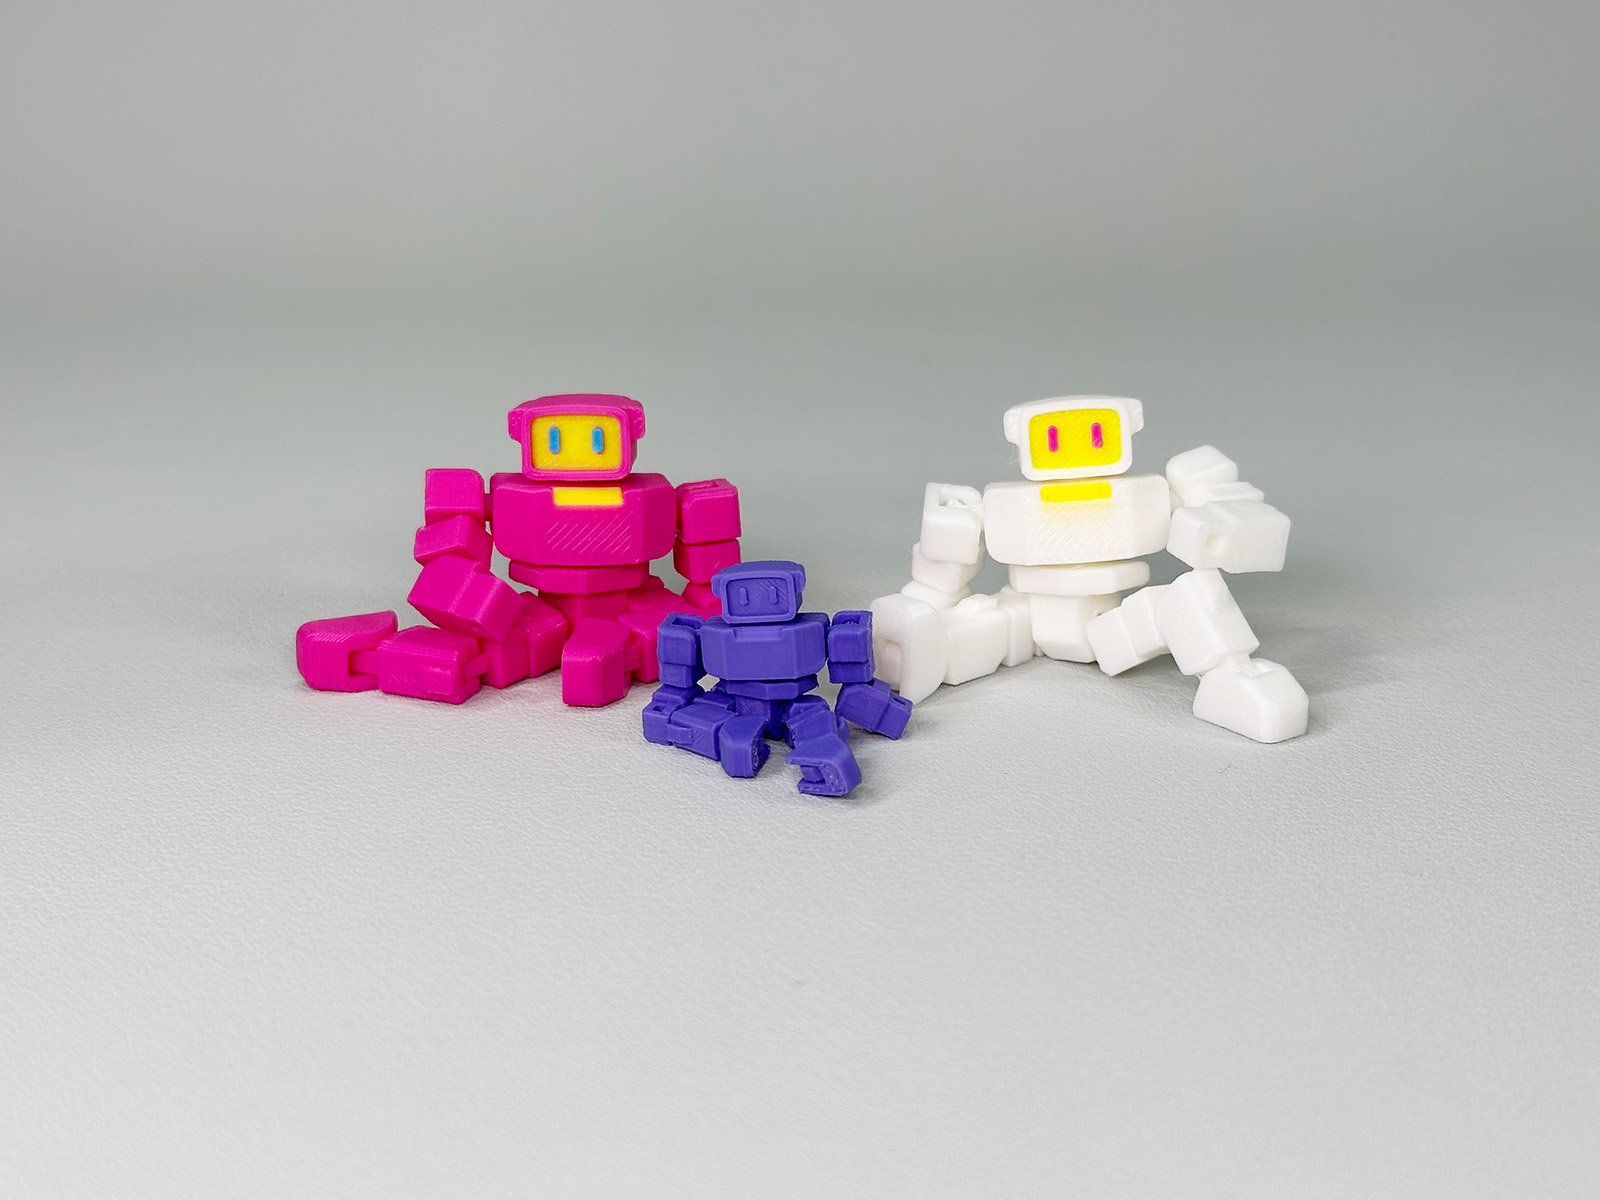
Tips:
When printing the 0.2mm version, please make sure to add a raft and do not set the printing speed too fast.
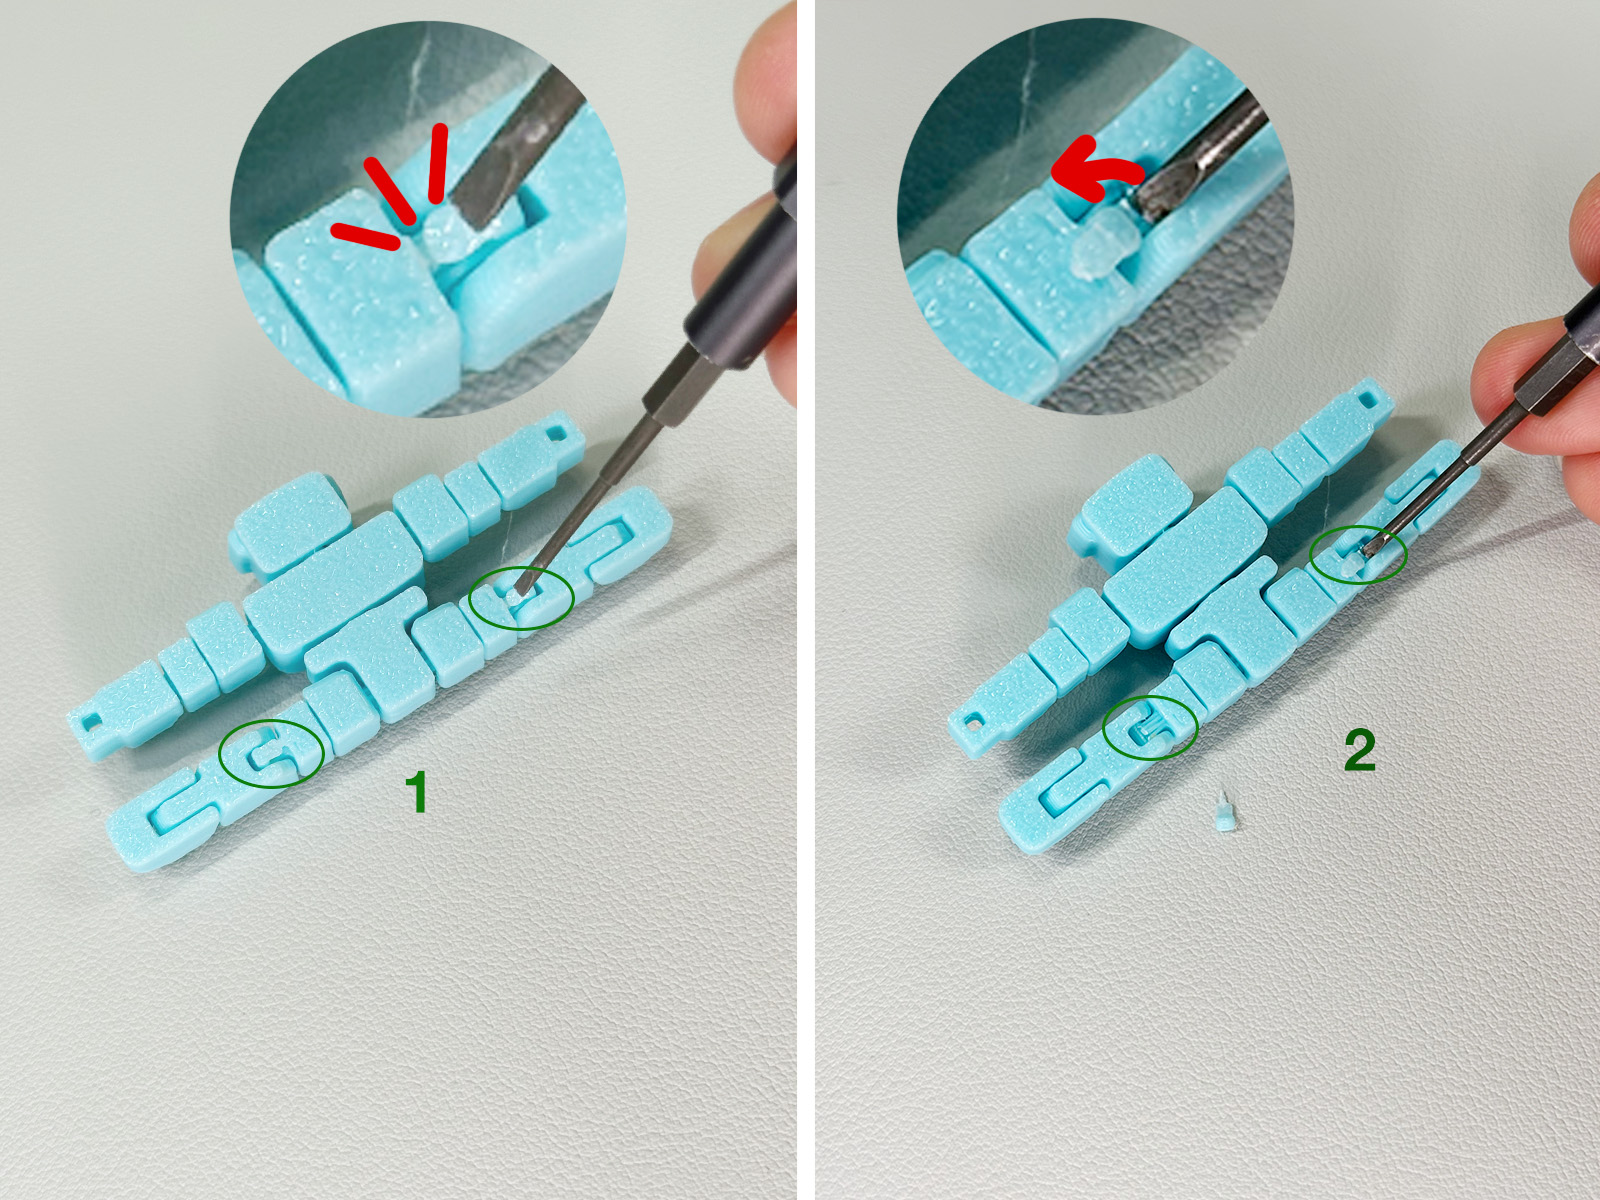
No additional support is required for printing. After printing, you can remove two parts in the order of 1 and 2 in the following picture.


💬MakerWorld Community Comments(1232)
★MakerWorld Original Reviews